
Your phone rotates the screen as you turn it. A fitness watch counts steps while filtering out random hand movements. A car can recognize a sudden impact and trigger a safety system in milliseconds.
These functions feel like ordinary software features, but each begins with a physical measurement. Somewhere inside the device, a tiny structure detects motion, pressure, sound, or changes in the surrounding environment.
That structure is often a MEMS device: a microelectromechanical system. MEMS technology combines miniature mechanical parts with electronics, allowing silicon chips to sense the physical world at remarkable scale.
Understanding MEMS helps explain why modern electronics can be responsive, compact, and energy-efficient—and why a sensor that looks simple on a circuit diagram can be one of the most sophisticated parts in a product.
🔬 What MEMS Technology Means
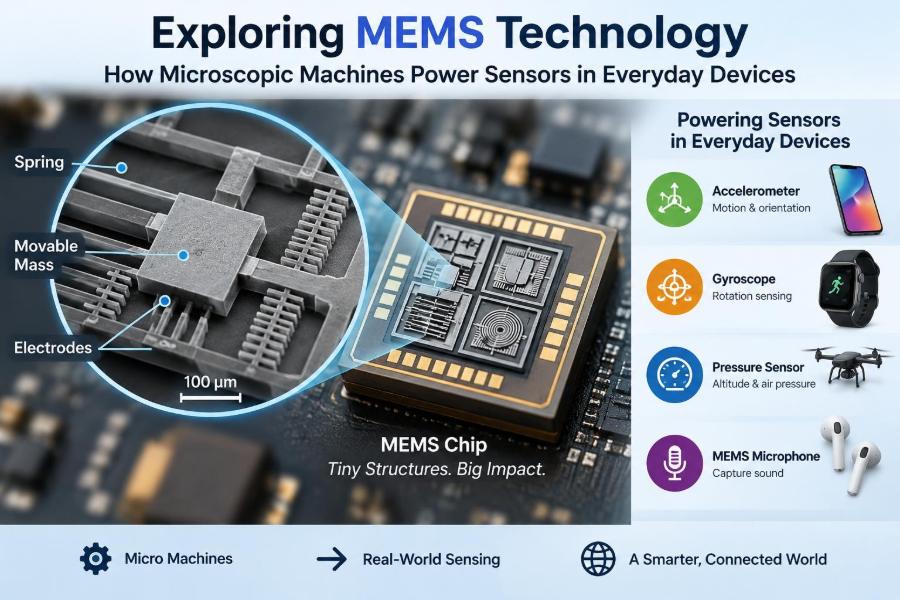
MEMS stands for microelectromechanical systems. These are devices containing mechanical elements—such as beams, membranes, springs, masses, or tiny cavities—fabricated at microscopic dimensions and integrated with electronic circuitry.
The mechanical structure responds to a physical input. Electronics then convert that response into an electrical signal that a microcontroller, processor, or control system can interpret.
📏 The Scale of a Microscopic Machine
MEMS features are commonly measured in micrometres, or microns. One micrometre is one millionth of a metre. A MEMS structure may therefore be far too small to inspect without magnification, even though the sensor package itself is visible on a circuit board.
Small size does not mean simple behavior. At this scale, surface forces, material stress, damping by air, and manufacturing variation can strongly affect performance.
⚙️ Mechanical Structures Built on Silicon
Silicon is familiar as the basis of integrated circuits, but it also has useful mechanical properties. It can form precise, repeatable structures that behave as springs, proof masses, diaphragms, and resonators.
A typical MEMS sensor has a mechanical sensing element, electrical electrodes or transducers, signal-conditioning circuits, and protective packaging. The complete component may also include a digital interface such as I²C or SPI.
🌉 A Useful Analogy: A Tiny Spring Scale
Many MEMS sensors can be understood as miniature spring scales. Apply a force, and a suspended mass moves slightly. Measure that displacement accurately, and the system can infer acceleration, pressure, or another physical quantity.
The displacement may be extremely small. The engineering challenge is not merely making it move; it is measuring movement reliably while rejecting vibration, electrical noise, temperature changes, and drift.
🏭 Why Semiconductor Manufacturing Changed Sensors
Conventional sensors were often assembled from separate mechanical and electronic parts. MEMS fabrication adapts semiconductor processes to create many microscopic structures across a wafer, enabling repeatable production and compact integration.
Photolithography patterns features, deposition adds material layers, and etching removes selected material. These methods make intricate shapes possible, although the exact process flow differs widely among sensor types and manufacturers.
🧱 Layers, Patterns, and Etching
A simplified MEMS process starts by depositing or growing material on a wafer. A light-sensitive coating called photoresist is patterned through a mask, transferring a geometric design to the surface.
Etching then removes exposed regions. Some processes create deep cavities; others release movable structures by removing a sacrificial layer underneath them. The result can be a suspended beam or mass with carefully controlled gaps.
🌀 The Accelerometer: Measuring Linear Motion
A MEMS accelerometer measures specific force, including the effect of gravity. In a phone resting flat, it detects approximately one g due to gravity; during motion, the reading also reflects acceleration of the device.
Inside, a proof mass is suspended by flexures. When the package accelerates, inertia causes a relative displacement between the mass and the surrounding frame. Electronics measure that displacement along one, two, or three axes.
📱 Why Phones Know Which Way Is Up
Screen rotation is a practical accelerometer application. Software estimates the gravity direction from sensor readings and determines whether the phone is held in portrait or landscape orientation.
This is not always instantaneous because quick gestures and vibration can resemble a change in orientation. Filtering and timing logic help distinguish a deliberate rotation from brief movement.
🧭 The Gyroscope: Measuring Rotation
A MEMS gyroscope measures angular rate: how quickly an object rotates around an axis. Unlike an accelerometer, it does not directly reveal the direction of gravity.
Many MEMS gyroscopes use a vibrating structure. Rotation produces a tiny Coriolis effect that shifts vibration into another direction. Capacitive sensing detects this shift and converts it into an angular-rate signal.
🧩 Why Accelerometers and Gyroscopes Work Together
Each sensor has limitations. Accelerometers can estimate tilt over longer periods but are disturbed by linear motion. Gyroscopes respond well to rapid rotation but small biases accumulate when their output is integrated over time.
Sensor fusion combines their strengths. A complementary filter or more advanced estimation method can use gyroscope data for fast changes and accelerometer data for longer-term correction.
🧭 What an IMU Actually Contains
An inertial measurement unit, or IMU, commonly combines a three-axis accelerometer and three-axis gyroscope. Some IMUs also include a magnetometer, temperature sensor, and embedded processing functions.
An IMU does not automatically provide perfect position tracking. Position requires integrating acceleration twice, so even small errors can grow quickly. Useful navigation systems usually need additional references, such as GNSS, wheel sensors, cameras, or known landmarks.
🎤 MEMS Microphones Turn Pressure into Audio
A MEMS microphone uses a flexible diaphragm and a fixed backplate. Sound pressure moves the diaphragm, changing the capacitance between the two surfaces.
An integrated circuit amplifies and conditions the resulting signal. The tiny package, consistent manufacturing, and compatibility with digital audio systems have made MEMS microphones common in phones, earbuds, laptops, and voice-control devices.
🌦️ Pressure Sensors and the Flexible Diaphragm
MEMS pressure sensors often use a thin diaphragm over a reference cavity. Pressure bends the diaphragm, changing piezoresistors or capacitance. That change can be calibrated into a pressure reading.
In a smartwatch or phone, a barometric pressure sensor can support altitude-related estimates. In industrial equipment, pressure sensing may monitor pneumatic lines, fluid systems, or process conditions. The required accuracy and environmental protection differ greatly between these uses.
🚗 Automotive MEMS: Fast Measurements for Safety
Cars use MEMS sensors for functions including airbag deployment sensing, vehicle stability control, tire-pressure monitoring, cabin pressure measurement, and engine or drivetrain management.
Automotive use is demanding because sensors face temperature extremes, humidity, vibration, electromagnetic interference, and long service lifetimes. A component suitable for a consumer gadget is not automatically appropriate for a safety-related automotive function.
🩺 Medical and Wearable Applications
Wearables use accelerometers and gyroscopes to estimate activity, identify posture patterns, and support gesture interfaces. Some medical instruments use MEMS pressure sensors, microphones, pumps, or microfluidic structures.
Sensor data alone does not equal a diagnosis. Motion artifacts, placement, individual variation, and algorithm design can affect interpretation. Medical applications require validation and regulatory considerations appropriate to their intended use.
🏠 MEMS in Smart Home Devices
A smart speaker may use a microphone array to capture speech from different directions. A robot vacuum can use inertial sensing to help interpret its movement. Security and environmental devices may combine pressure, motion, and acoustic sensing.
These applications illustrate a central idea: MEMS supplies raw measurements. The device becomes useful when firmware and algorithms turn those measurements into decisions or actions.
📡 Capacitive Sensing: Measuring Tiny Gaps
Capacitive sensing is widely used in MEMS accelerometers, gyroscopes, and microphones. Capacitance changes when conductive plates move closer together, farther apart, or overlap by a different amount.
Because the changes can be very small, the readout circuit must be designed carefully. Parasitic capacitance from interconnects, package structures, and moisture can influence the measurement if not controlled.
🧲 Piezoresistive and Piezoelectric Approaches
Not all MEMS devices use capacitance. In piezoresistive sensing, mechanical strain changes a material’s electrical resistance. This approach is common in certain pressure-sensing structures.
Piezoelectric materials generate charge when stressed and deform when an electric field is applied. They can support sensing or actuation, particularly where dynamic vibration or ultrasound is involved. Material choice depends on the measurement range, noise needs, power budget, and fabrication process.
🔊 MEMS as Actuators, Not Just Sensors
MEMS can create motion as well as detect it. Examples include micro-mirrors for optical systems, resonators used for timing, inkjet structures, and tiny pumps or valves for specialized fluid handling.
This distinction matters: a sensor converts a physical quantity into information, while an actuator converts electrical control into physical action. Some systems contain both.
📦 Packaging Is Part of the Engineering
A MEMS die is fragile and sensitive to its surroundings. Packaging must protect it from contamination and mechanical damage while still allowing the intended input to reach the sensing structure.
A microphone needs an acoustic port. A pressure sensor may need access to air or fluid. An inertial sensor often needs a controlled internal environment so damping remains predictable. Package stress can also shift sensor readings.
🌡️ Temperature, Bias, and Drift
Real sensors are imperfect. Bias is an offset present even when the ideal input is zero. Sensitivity describes how much output changes for a given input. Both can vary with temperature, aging, supply voltage, and mechanical stress.
Drift is especially significant when a signal is integrated over time. A small gyro bias, for example, can become a noticeable orientation error. Calibration and filtering reduce errors but cannot remove every limitation.
🎛️ Calibration Turns a Signal into a Measurement
Calibration relates a sensor’s raw output to known physical inputs. It may compensate for offset, scale factor, axis misalignment, nonlinearity, and temperature behavior.
Factory calibration is common, but some devices also support user or system calibration. A compass application that asks a user to move a phone through several orientations is collecting data to improve magnetic-field interpretation; it is not a universal fix for every sensor error.
📉 Noise, Resolution, and Bandwidth
Noise is random variation in an output. Resolution is the smallest useful change a system can distinguish, while bandwidth describes the frequency range it can meaningfully track. These terms are related but not interchangeable.
Increasing bandwidth may admit more noise. Heavy filtering can produce smoother output but delay the response. Engineers choose a trade-off based on the application: a step counter, a drone stabilizer, and a machine-vibration monitor need different behavior.
🔋 Power Consumption Matters at Small Scale
MEMS sensing elements can be compact, but the total energy use also includes analog front ends, digital conversion, processor activity, and data transmission. Battery-powered products therefore use duty cycling, low-power modes, and motion-triggered wake-up features.
Sampling a sensor continuously at a high rate is not always better. It can waste energy and generate data that the application cannot use.
🧠 From Raw Data to Useful Features
A sensor register may provide a sequence of numbers, not a direct answer such as “the user is walking.” Software must remove offset, apply scale factors, filter noise, detect events, and classify patterns.
For example, a fall-detection feature may look for a combination of acceleration, orientation change, timing, and subsequent inactivity. A single large acceleration peak could simply be a dropped device, so robust systems consider context.
🛠️ Practical Design Choices for Engineers
When selecting a MEMS sensor, start with the physical question rather than the package or interface. Define the measurement range, required bandwidth, acceptable noise, operating temperature, power budget, mounting constraints, and failure consequences.
- Choose range with margin, but avoid needlessly large range that reduces usable sensitivity.
- Check whether data rates and digital filtering fit the control loop or application timing.
- Plan the PCB layout and mechanical mounting early, especially near vibration sources.
- Evaluate sensor behavior in the actual product enclosure, not only on an evaluation board.
⚠️ Common Integration Mistakes
A frequent mistake is treating a sensor breakout board as representative of final product performance. Board stiffness, connector vibration, enclosure resonance, heat sources, and nearby electrical noise can all change results.
Another mistake is assuming one nominal specification tells the entire story. Noise density, bias stability, cross-axis sensitivity, digital latency, startup behavior, and calibration requirements may matter as much as full-scale range.
🧪 Testing Under Real Conditions
Bench testing should include expected orientations, vibration levels, temperatures, supply conditions, and operating modes. For motion sensors, compare outputs with a suitable reference when accuracy is critical.
Tests should also consider abnormal conditions: shock, drops, blocked ports, condensation, electromagnetic disturbances, and rapid temperature transitions. The goal is not to eliminate every error, but to understand the error modes and design responsibly around them.
🔐 Privacy and Data Interpretation
MEMS data can reveal patterns of activity, movement, device handling, and environmental conditions. A raw accelerometer does not record conversations, but sensor streams combined with other data can still create sensitive inferences.
Product designers should collect only the sensing data needed for the function, protect stored and transmitted data, and communicate clearly about how data is used. Good engineering includes responsible system design, not only component performance.
🚀 Where MEMS Technology Is Heading
Development continues toward improved integration, lower noise, reduced power use, and sensors that combine multiple functions in smaller packages. Emerging applications include precision robotics, mixed-reality devices, condition monitoring, compact optical systems, and specialized biomedical tools.
Progress is not simply a race to make every feature smaller. Better packaging, calibration, algorithms, and application-specific design are often just as valuable as shrinking the mechanical structure.
🧠 The Core Principle: Physical Motion Becomes Digital Insight
MEMS technology works because carefully engineered microscopic structures respond predictably to forces, pressure, sound, and motion. Electronic circuits detect those tiny mechanical changes, while software turns the signals into useful information.
The most effective MEMS-based product treats the sensor as part of a complete measurement chain: physical input, mechanical response, electrical readout, calibration, filtering, interpretation, and action. Weakness at any stage can limit the final result.
Microscopic machines matter because they give electronics a practical way to sense the real world—one precisely measured movement, vibration, pressure change, or sound wave at a time. 🔌🔬📱